A/Upakandee
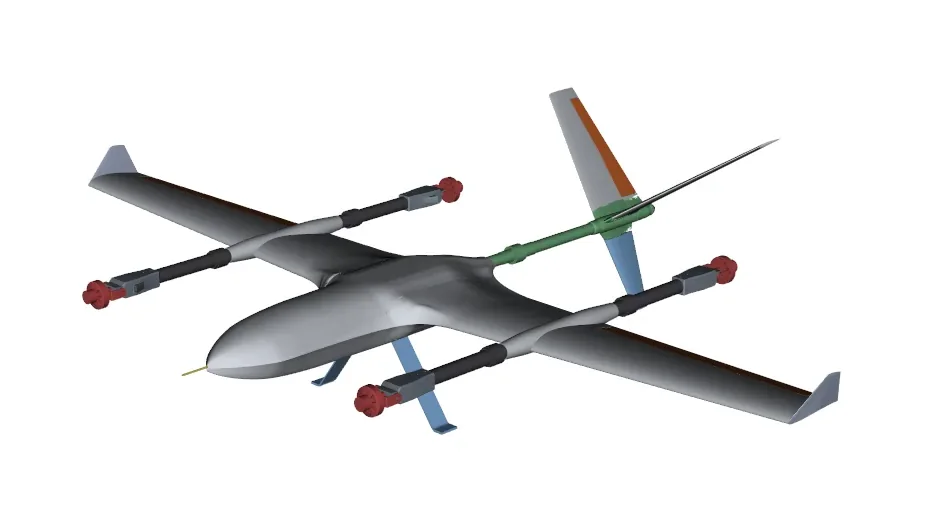
R26 quad tilt-rotor VTOL UAV designed by Autsadawut Upakandee

■ B.Eng. Aerospace · KMUTNB · class of 2027

Autsadawut Upakandee

I design UAVs, build them with my hands, and make them fly.

40KB-5E UAVs integrated for the Royal Thai Air Force at TAI
1STAAVC 2026, national autonomous UAV challenge, as team technician
73parts in my R26 SolidWorks assembly, clash-checked every revision
2.04Mwingspan VTOL, taken from first sizing to CNC-ready parts

01  Senior project · 2026 – now

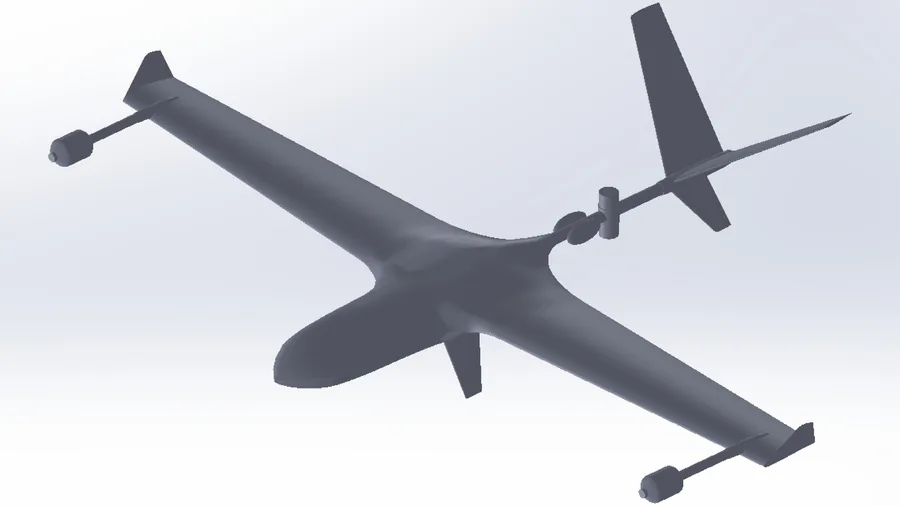
R26 Quad Tilt-Rotor VTOL

It takes off and lands like a drone, then tilts all four rotors forward to cruise on the wing like an airplane. Design is closed and the team is building it now.

2 041
Underside view, rev v84. Span over winglets, mm.
My part
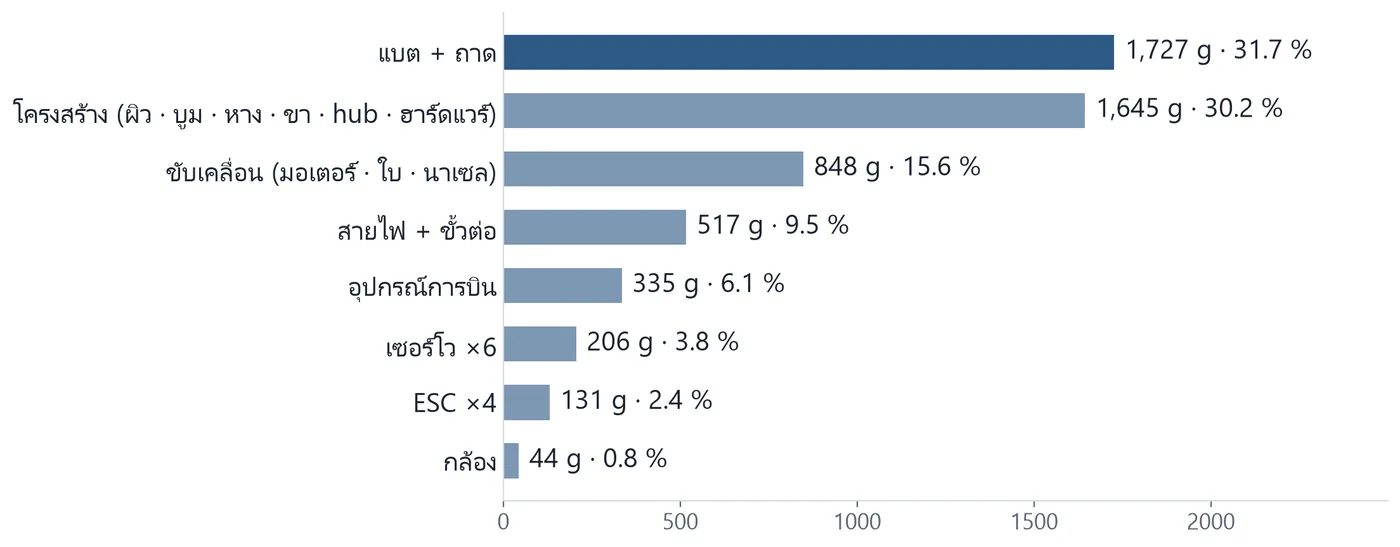
Sizing and weight budget, the structure, and the complete SolidWorks assembly
Config
Quad tilt-rotor VTOL, high wing, Y-tail
Mass
6.63 kg take-off · thrust-to-weight 2.10
Structure
2 mm foam core with carbon faces, cut as plates that slot together
Checks
73 parts, zero clashes above 1 mm³ at every revision
Tools
OpenVSP, XFLR5, Python, SolidWorks
Open the full 3D assembly, wiring and layup ↗
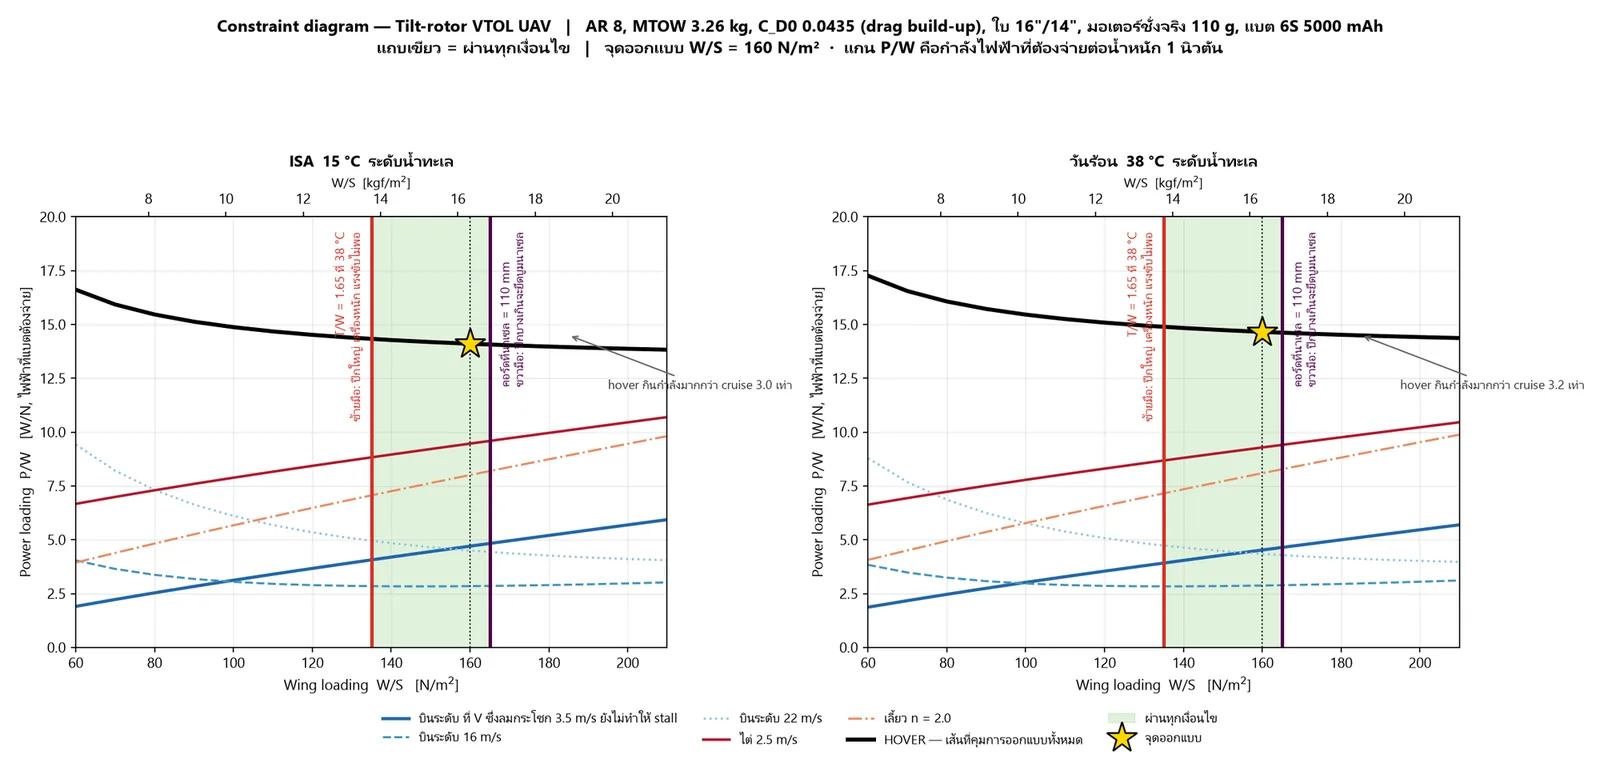
  1. Size itConstraint diagram to pick the design point, then a weight budget for every part.
  2. Shape itAirfoil, tail and control surfaces sized around that point.
  3. Structure itCarbon-faced foam plates that lock into each other, so the airframe lines itself up.
  4. Assemble & checkFull SolidWorks assembly, interference-checked, exported for CNC.

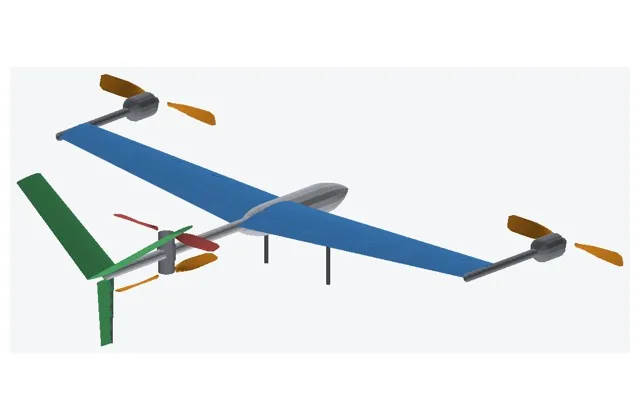
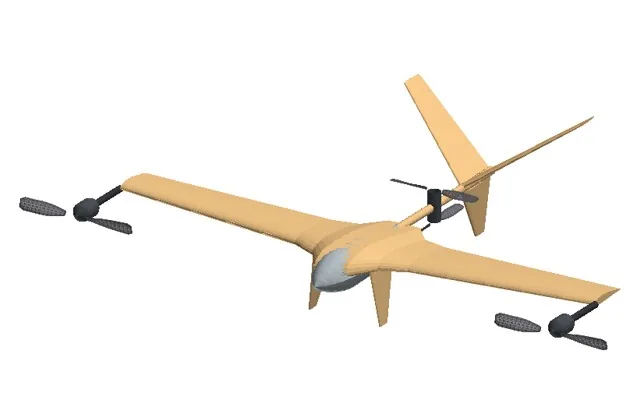
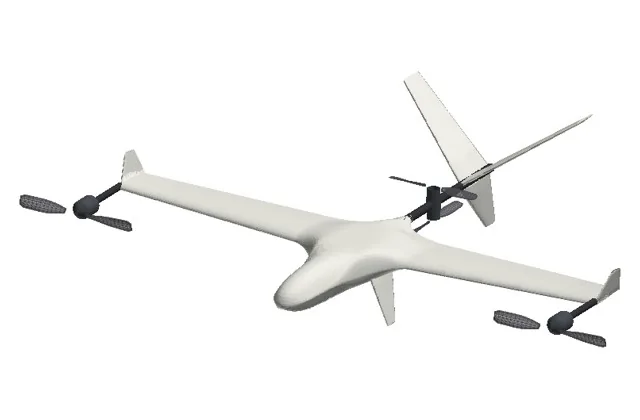
From concept to R26

Early concept in OpenVSP
Concept, OpenVSP
Second iteration
Iteration
Blended body iteration
Blended body
R23 in SolidWorks
R23, SolidWorks
Final R26
R26, final

Engineering behind it

Constraint diagram used to choose the design point
Constraint diagram → design point
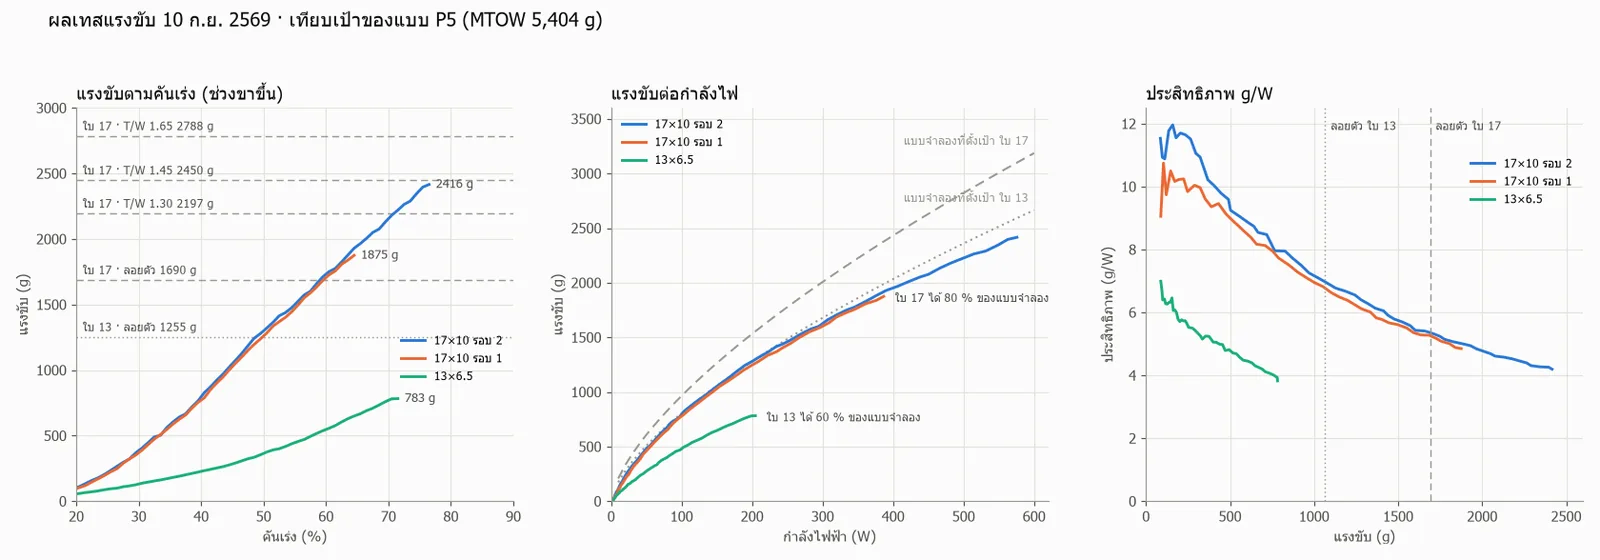
Static thrust bench test charts
Static thrust bench test
Mass budget by subsystem

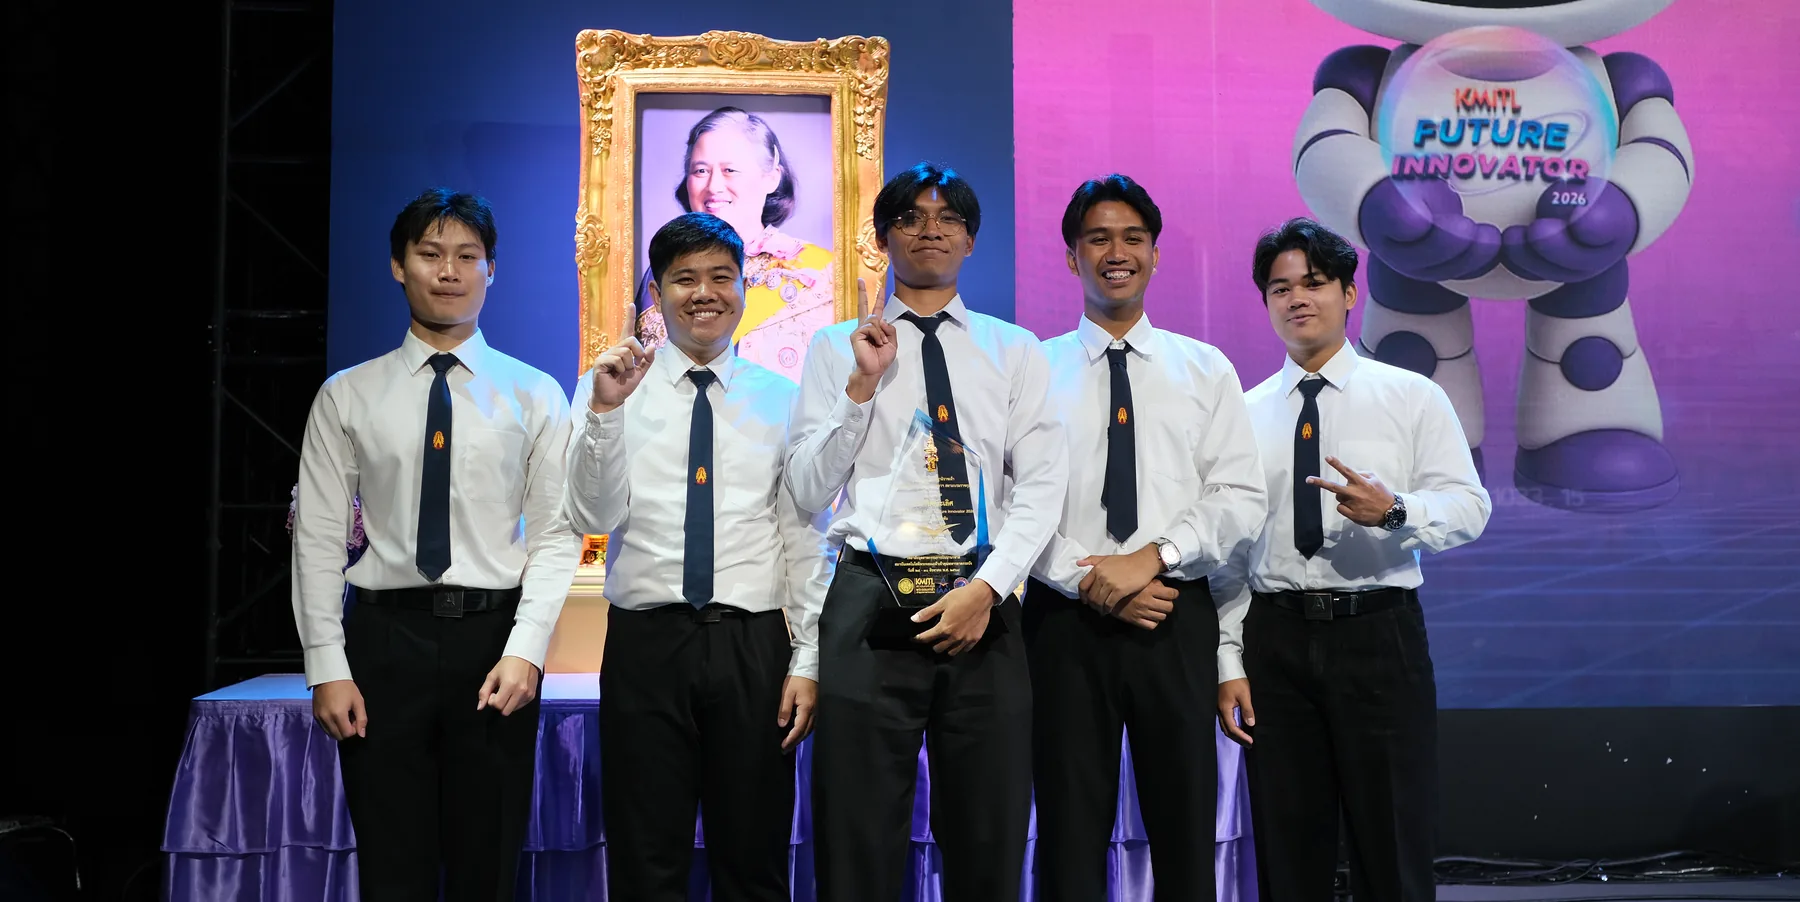
02  Award · Aug 2026 · IAAI, KMITL

Autonomous Aerial Vehicle Challenge 2026

The winning team on stage with the AAVC 2026 trophy
My role · team technician

I soldered and wired the drone's electrical system, and fixed problems on the spot when things broke during the competition.

AAVC is Thailand's inter-university UAV competition, run by the Consortium of Aerospace Engineering since 1997. Our team took first place.

2026 mission · no pilot input

  1. Carry a raw egg into the search area
  2. Find the right pad by its marker, using the camera
  3. Land and release the egg without breaking it
  4. Take off again and fly home

03  Internship · Apr – May 2026 · Thai Aviation Industries

UAV Integration Engineer, Intern

On the production team that delivered 40 KB-5E UAVs to the Royal Thai Air Force. My work on each aircraft:

  1. AirframeHardware fastened to spec, propellers fitted
  2. PowerESC power wiring and connectors soldered
  3. AvionicsInstalled and wired, routed to a clean layout
  4. ControlsServo movement and direction checked
  5. HandoverPitot covers made, aircraft ready for delivery
PHOTOS WITHHELD

Defence programme. Also at TAI: Diamond DA42 familiarisation, aircraft towing and engine ground runs.

04  Personal startup project · Oct 2026 – now

VerseStarTrack

A 6DOF head tracker for flight simulators. Turn your head and the cockpit view follows: an ESP32 IMU on the headset is fused with webcam face tracking, so the view stays fast and does not drift.

  • Started with market research: webcam-only trackers lag about 50–80 ms behind your head. Fusing an IMU closes that gap.
  • Built the hardware, the tracking software in Python and a Windows desktop app, then tested it in the DCS World flight simulator.
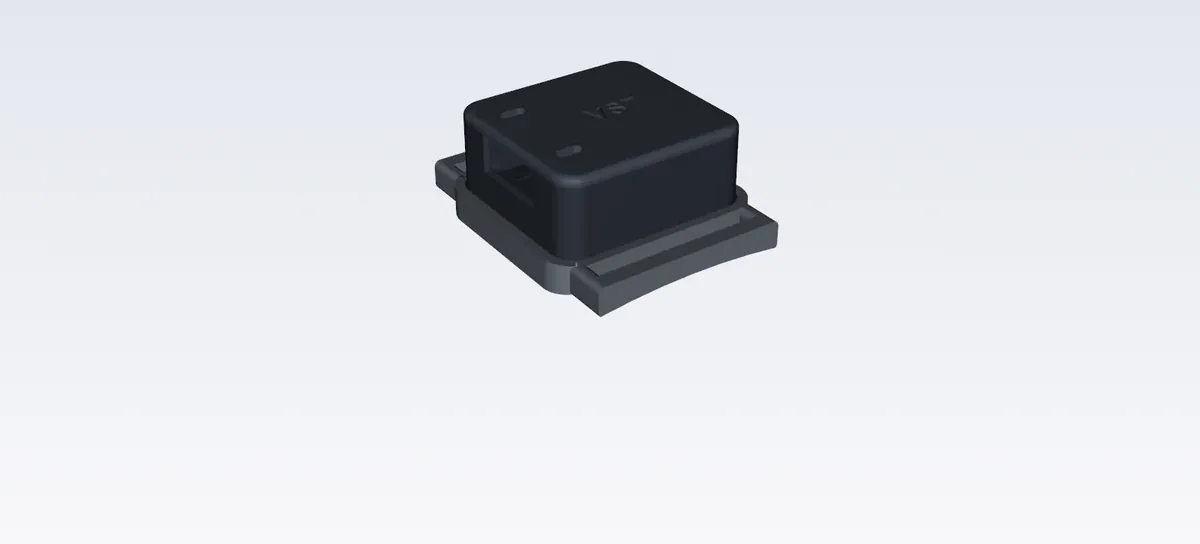
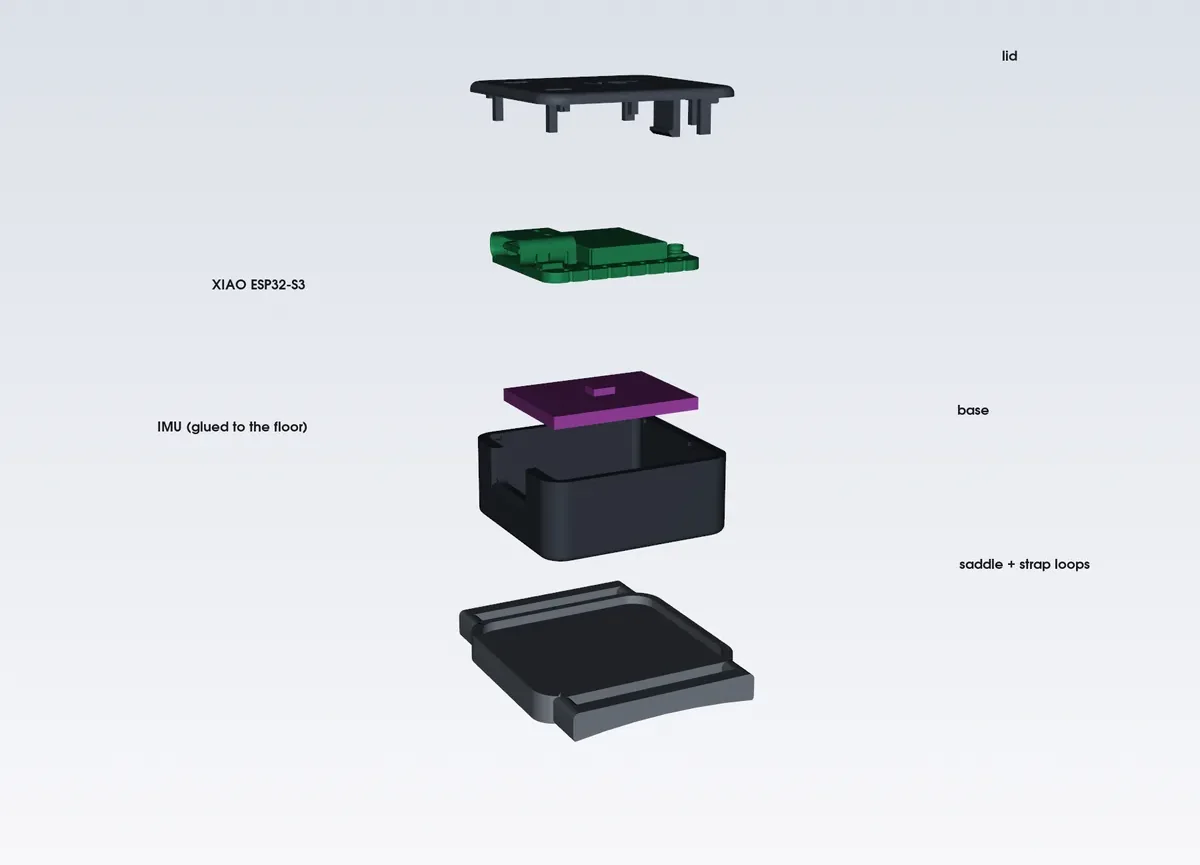
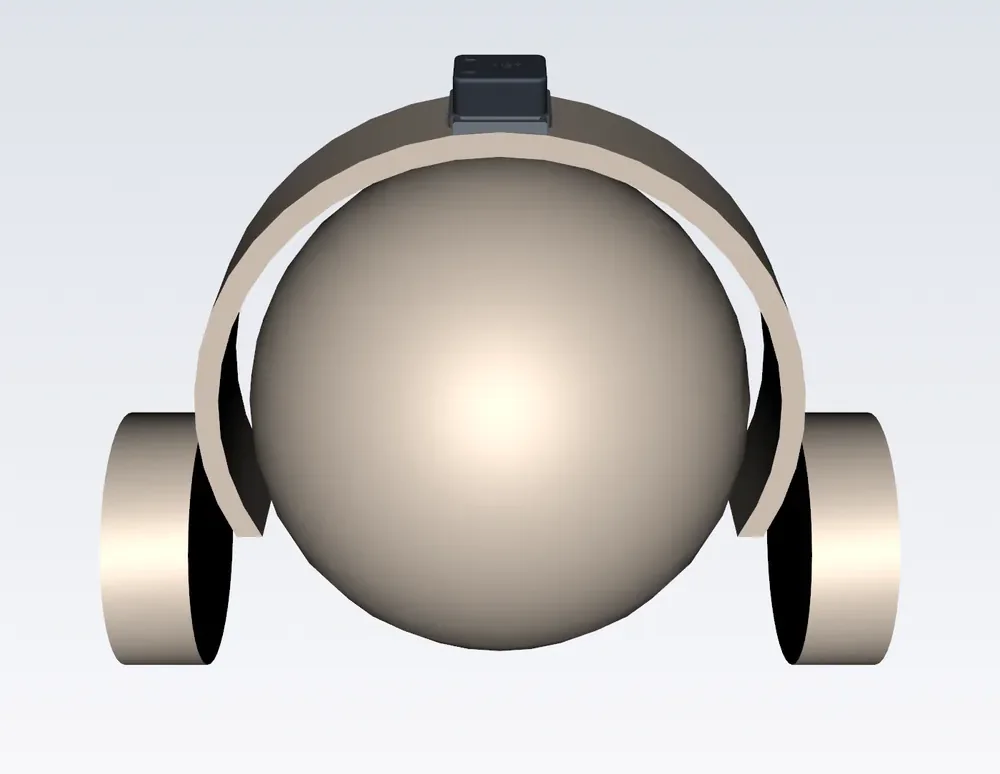
  • Designed a 3D-printed sensor pod that clips onto a headset.
  • ESP32-S3
  • IMU sensor fusion
  • Python
  • Computer vision
  • 3D printing
Sensor pod render
Sensor pod
Exploded view of the pod
Exploded
Pod on a headset
On headset

05  Personal projects · 2026

Drones, control & tools

Building now

KESTREL-4 autonomous quadcopter

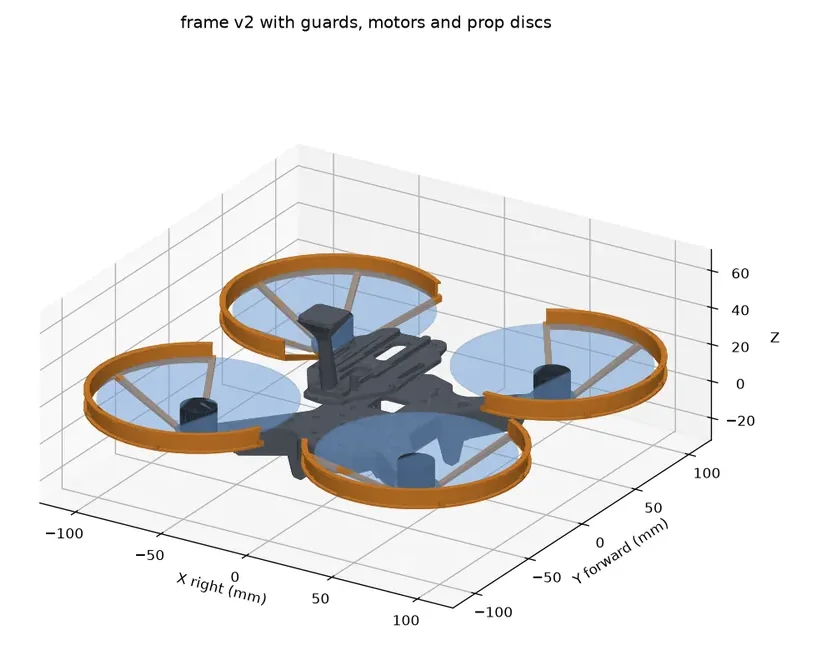
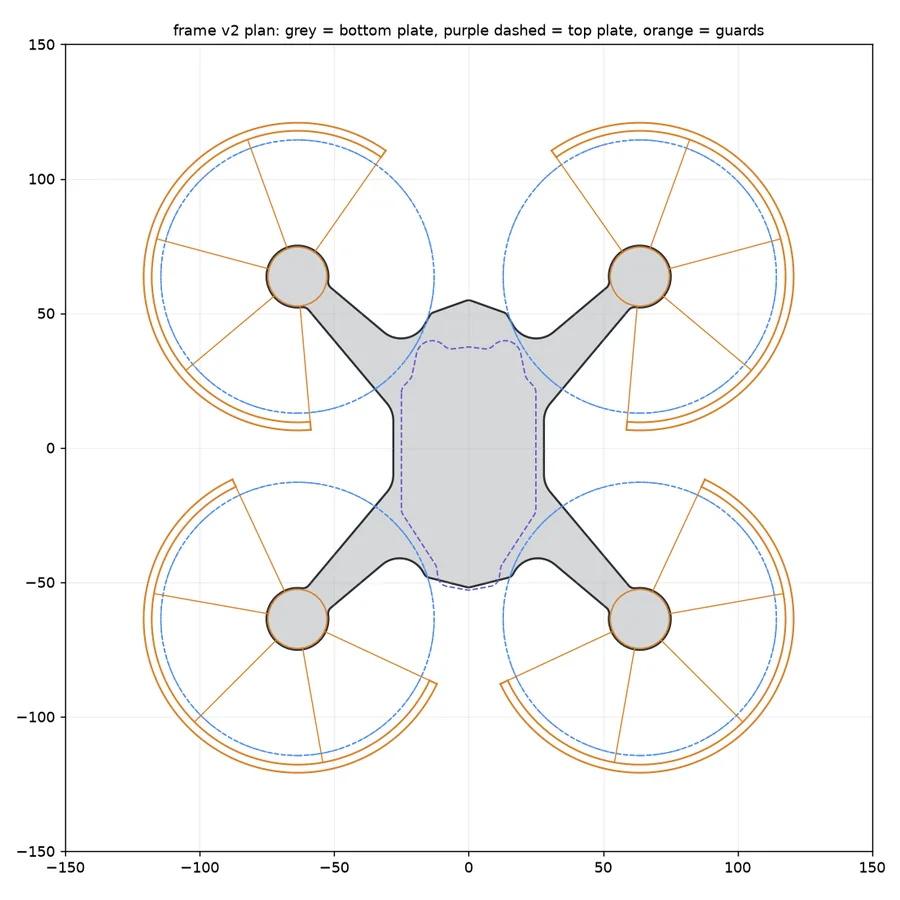
My own ArduPilot quadcopter on a ducted, 3D-printed frame I designed. Goal: GPS position hold and autonomous waypoint flight, as a test bed for flight control.
  • ArduPilot
  • H743 flight controller
  • GPS
  • 3D printing
KESTREL-4 frame with prop guards KESTREL-4 frame plan drawing
Flight control

ESP32 quad PID tuning

Tuned the attitude PID loops of an ESP32 quadcopter running a custom flight controller.

CAD automation

Wing rib generator

A SolidWorks add-in I am building: OpenVSP wing in, ribs with spar slots and lightening holes out, as DXF for laser cutting.

Electronics

Sim control box

Built a button-box controller for flight simulators with Arduino.

Since 2023

Aeroptix Club

Design, build and fly drones and gliders with the club team, using OpenVSP, SolidWorks and XFLR5.

Outreach

University Open House

Explain aircraft controls and aerodynamics to visitors in a flight simulator with head tracking.

06  Toolbox

Systems I work with

Design & CAD

  • SolidWorks
  • OpenVSP
  • Composite structures
  • Technical drawing

Analysis

  • ANSYS, Abaqus FEA
  • XFLR5 / Flow5
  • MATLAB / Simulink
  • Python

Build & test

  • UAV assembly
  • Avionics integration
  • Soldering, wiring
  • 3D printing, CNC
  • Flight testing

Flight control

  • PID tuning
  • ArduPilot
  • ESP32 / Arduino
  • Aircraft dynamics